Embodied First Exam
Benchmark suite for code agents controlling robots in physical tasks
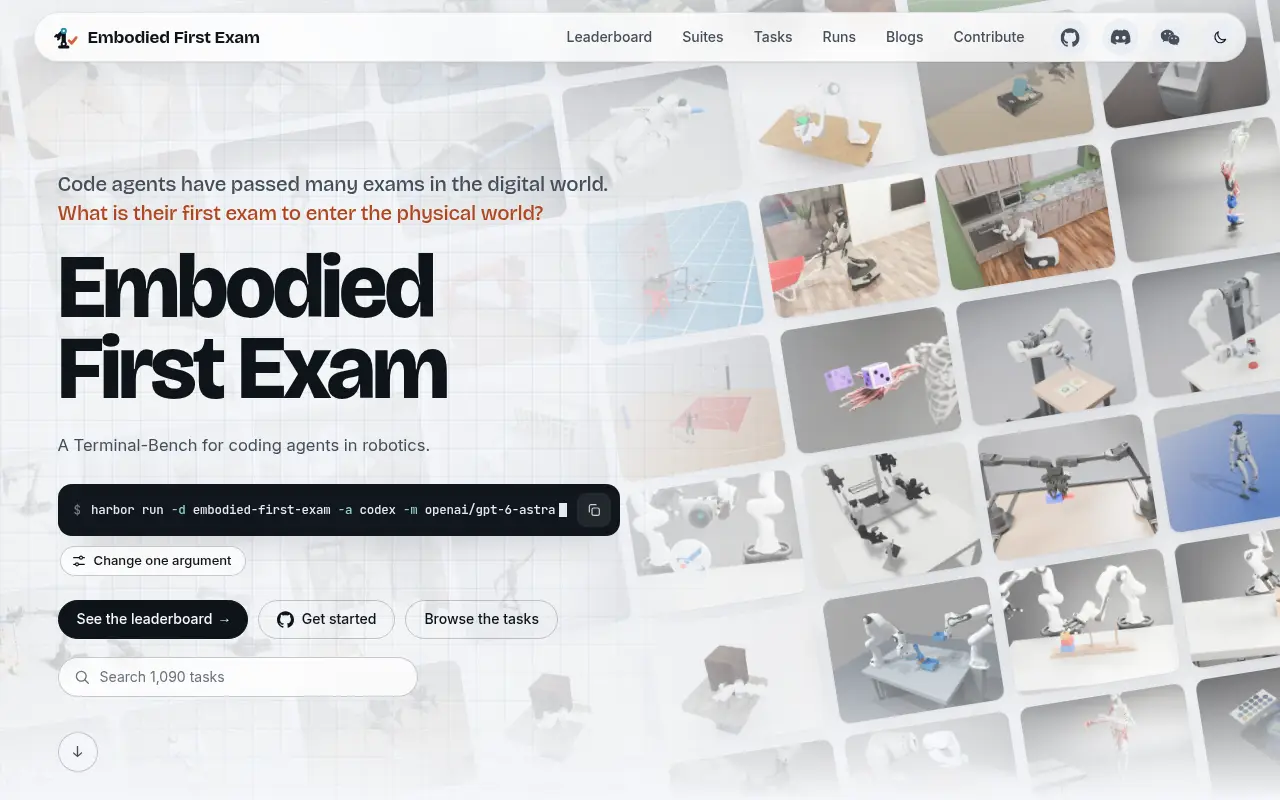 Visit embodied-first-exam.ai ↗
What is Embodied First Exam?
Embodied First Exam is a leaderboard and evaluation framework for testing code agents on physical robot tasks. It combines multiple benchmark suites including RoboPaint, RoboARC, DexHand, and Embodied Olympics, where agents write programs to control robot arms and manipulators. Tasks are frozen from existing benchmarks and marked by replay, providing a unified framework for comparing agent performance across diverse physical manipulation challenges. Built with Claude Code.
Momentum
Daily activity over the last 30 days: upvotes, unique visits, new GitHub stars and Hacker News points.
How do we know it's vibe coded?
vibetrend discovered Embodied First Exam automatically. Evidence: Rising on GitHub: agent files (claude-code) in mll-lab-nu/embodied-first-exam. View source.
Similar vibe-coded apps
Open-source platform for orchestrating data, AI, and infrastructure workflows
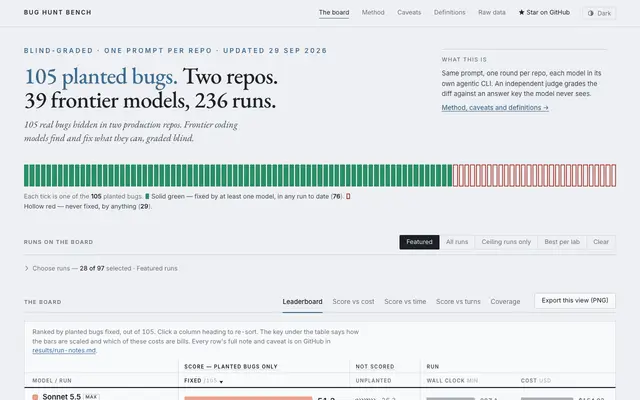
Blind-graded benchmark of AI coding models on real planted bugs
Remote MCP server connecting AI agents to data from 91 platforms
Graph database on object storage, built for AI agent memory and context
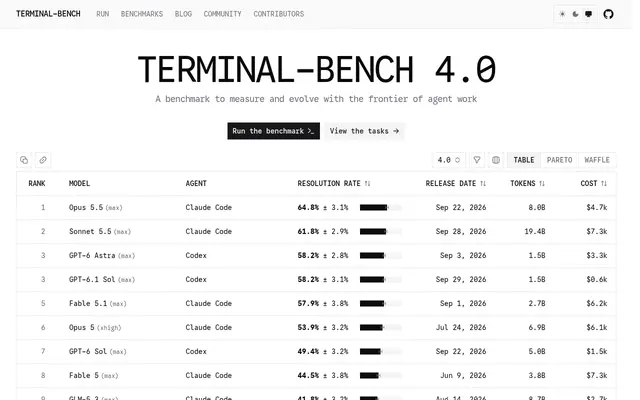
Benchmark for testing AI agents in real terminal environments
Benchmark measuring how well AI agents can improve base language models
Evaluation layer for AI analytics with governed ground truth and drift detection